
Classify Low Points
Brief
The low point refers to the noise point that is lower than the actual terrain. Low points interfere with ground point extraction, because the progressive triangulation filtering algorithm builds on seed points located at the lowest point of the gridded point cloud. Therefore, filtering out low points is a preprocessing step that directly affects filtering results, digital model generation, and contour line quality. The triangulated terrain model created by the ground points with low points is shown below.
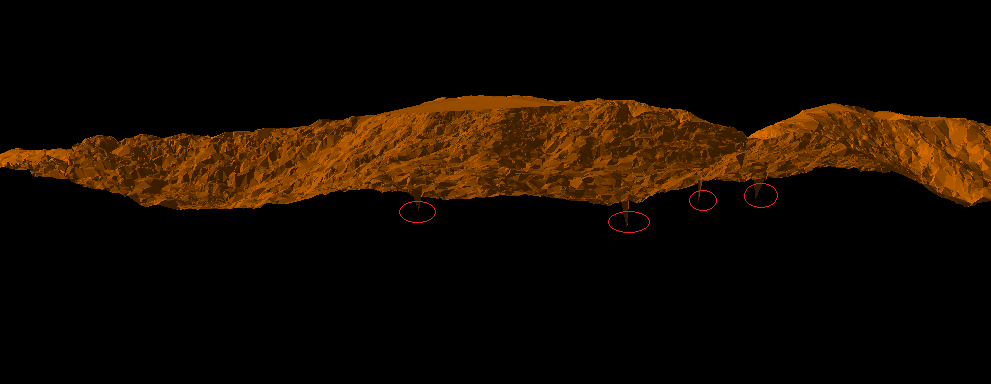
The distribution of low points is divided into individual points or clusters. The algorithmic flow of this function is:
- Traverse the point cloud and search for points to be classified within a certain range of radius of the current single point or point cluster.
- Calculate the maximum height difference between the current point and the neighboring point, which is compared with the threshold.
- If the value is greater than the threshold, the current point is considered to be a low point, otherwise, it is not classified as a low point.
Usage
Click Classify > Classify Low Points
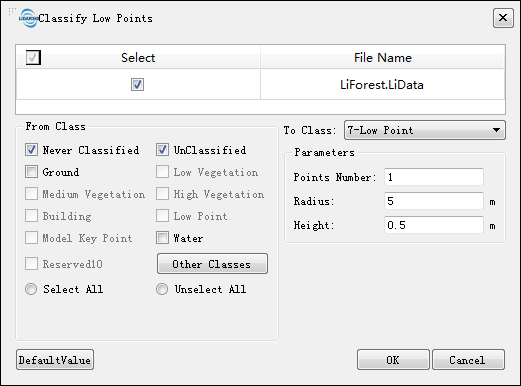
Settings
- Input Data: The input file can be a single point cloud data or a point cloud dataset, which must be opened in the LiPowerline software.
- From Class: Source class(es).
- To Class: Target class.
- Points Number (default value is "1"): When the number of points is set to 1, the single low point is classified. If it is greater than 1, cluster low points are classified.
- Radius (m, default value is"5"): The radius threshold between the unclassified point and the neighboring point.
- Height (m, default value is"0.5"): The height difference threshold between the unclassified point and the neighboring point.
- DefaultValue: Click this button to set all parameters as default.